Mohamad T. Shahab
about
research
publications
group
teaching
contact
Research
Adaptive & Learning-based Control
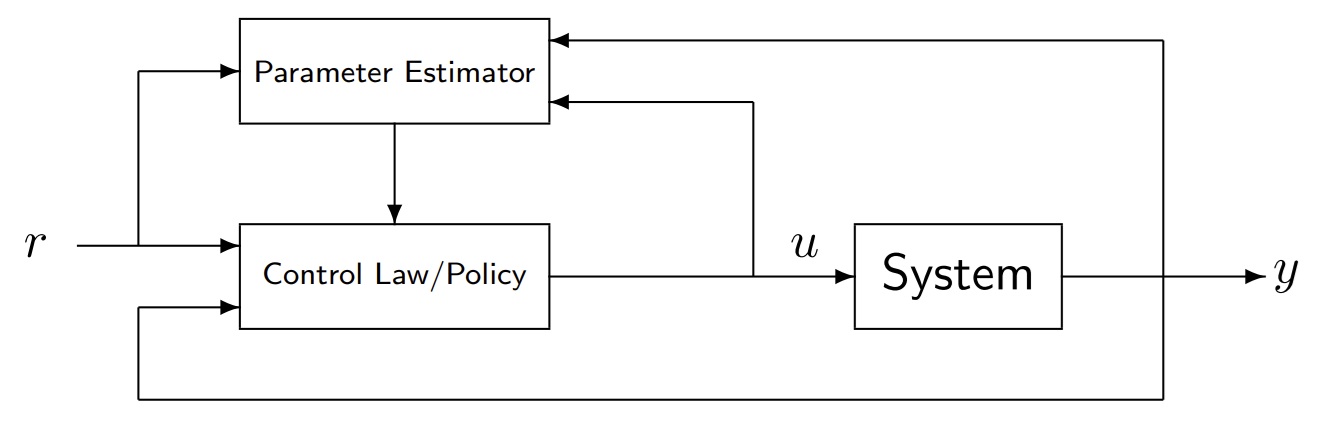
Guaranteeing performance of systems under uncertainty requires theoretical rigorous control design and analysis. We develop control policies and algorithms that enable systems to learn and adapt to improve their behavior. We leverage tools from control theory and machine learning to deliver predictable, robust and safer performance for next-generation autonomous systems.
Selected publications:
- M.T. Shahab, “Adaptive control with set-point tracking and linear-like closed-loop behavior,” IEEE Conference on Decision and Control (CDC), 2025
- M.T. Shahab, D.E. Miller, “Revisiting Model Reference Adaptive Control: Linear-Like Closed-Loop Behavior,” IEEE Transactions on Automatic Control, 2025
- M.T. Shahab, D.E. Miller, “Asymptotic Tracking and Linear-like Behavior Using Multi-Model Adaptive Control,” IEEE Transactions on Automatic Control, 2022
- M.T. Shahab, D.E. Miller, “Adaptive Control of a Class of Discrete-Time Nonlinear Systems Yielding Linear-like Behavior,” Automatica, 2021
Multi-Robot Systems under Uncertainty
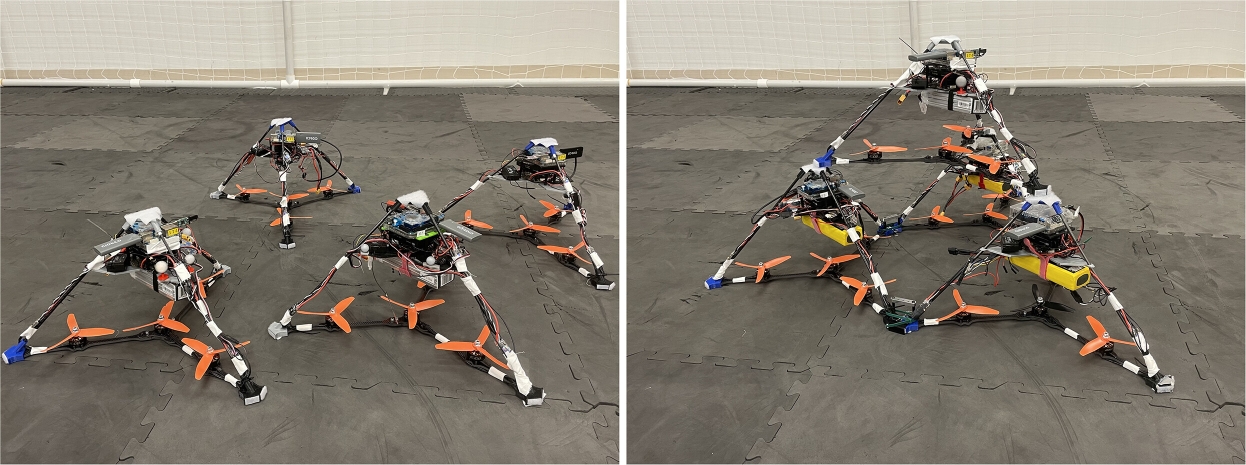
Robotic and autonomous systems operate in dynamic environments, where they may interact and/or collaborate with one another and with humans while responding to uncertainty and changing conditions. Developing robust cooperative and collaborative strategies are essential for enabling reliable and effective collective behavior.
Selected publications:
- O. Wali, E. Feron, M.T. Shahab and T. Khamvilai, “Control Strategies for a Modular Assembly of Tetrahedral-Shaped Multirotor Drones,” Journal of Guidance, Control, and Dynamics, 2025
- O. Wali, M.T. Shahab, E. Feron, “A Non-planar Assembly of Modular Tetrahedral-shaped Aerial Robots,” IEEE International Conference on Robotics and Automation (ICRA), 2023
- M.T. Shahab, K. Garanger, E. Feron, “Control of an Assembly of Aerial Vehicles under Uncertainty,” American Control Conference (ACC), 2022
- M.T. Shahab, M. Elshafei, “Distributed Optimization of Multi-Robot Motion with Time-Energy Criterion,” Path Planning for Autonomous Vehicles, 2019
Control & Optimization
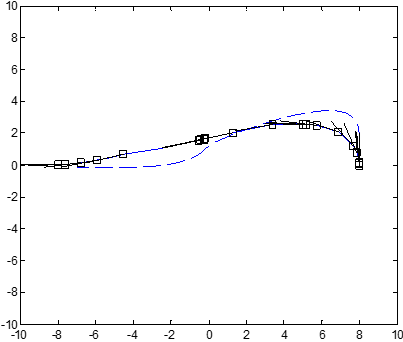
We develop optimization-based control methods that enable autonomous systems to plan and act reliably under uncertainty. By combining model predictive control, trajectory optimization, and constraint-aware planning with system dynamics and performance objectives, we seek solutions that are safe, robust, and effective in changing environments.
Selected publications:
- M.T. Shahab, M. Elshafei, “Distributed Optimization of Multi-Robot Motion with Time-Energy Criterion,” Path Planning for Autonomous Vehicles, 2019